About Me
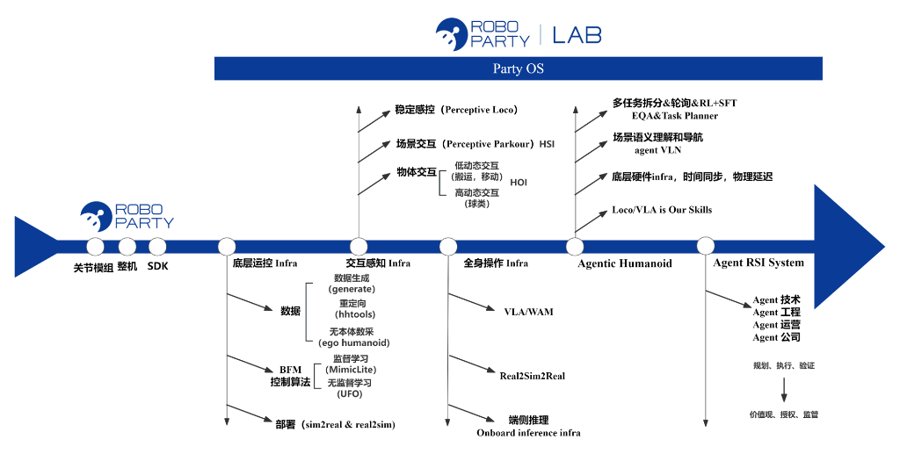
I lead RoboParty Lab at RoboParty, where we build open-source infrastructure and frontier algorithms for humanoid robots. The lab runs on four ideas: open source, SOTA operation, SOTA algorithms and a SOTA ecosystem.
Before RoboParty, I received my M.S. in Control Engineering from Zhejiang University, advised by Prof. Qiuguo Zhu at the Robotics and Machine Intelligence Lab, where I worked on humanoid model predictive control, imitation learning and reinforcement learning. I received my B.E. from Beijing Jiaotong University, where I captained the Robocon team and built legged robots from scratch.
My goal is to make the full pipeline from human data to real humanoid robots open, reproducible and easy to build on.
Research Interests
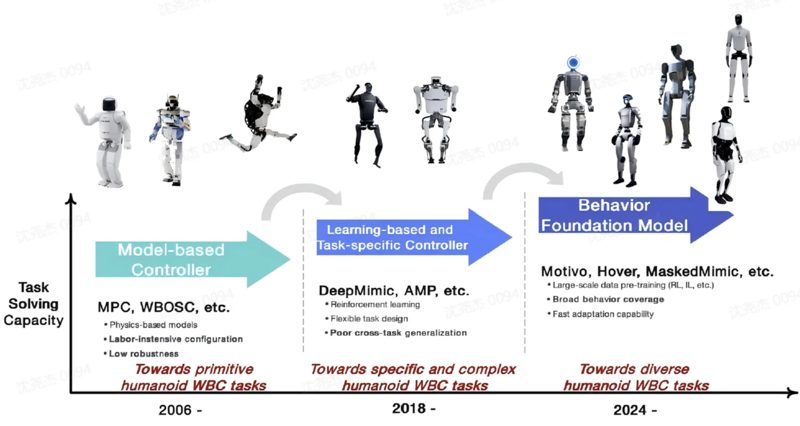
- Humanoid whole-body control: behavioral foundation models, unsupervised RL, motion imitation
- Human-to-humanoid data: motion retargeting, trajectory optimization, large-scale motion datasets
- Model-based control: centroidal-dynamics NMPC and whole-body control
- Open-source robotics: tools, systems and knowledge that lower the barrier to humanoid research
News
- [Oct. 2026] P-BFM is released: perceptive behavioral foundation models for terrain-adaptive humanoid control.
- [Oct. 2026] I-BFM is released: the first behavioral foundation model for humanoid–object interaction.
- [Sep. 2026] HHtools 0.1.0 Preview is out, with a desktop app, six built-in humanoids and agent-facing interfaces.
- [Mar. 2026] Graduated from Zhejiang University with an M.S. in Control Engineering.
Open Source
Open-source projects I lead: 420+ stars on GitHub
human-humanoid-tools (HHtools)
Retarget parkour, dance and interaction clips onto any humanoid in about 30 seconds. Supports any URDF, any motion dataset, robot-to-robot transfer, terrain and object interaction, batch processing and dataset analysis.
Building a Robot Electronics System from Scratch
My undergraduate blog series (24 posts, in Chinese). Starting from STM32, it covers power, sensors and motor selection, main-board design, MCU architecture, communication protocols, filtering and PID.
Publications
In submission
P-BFM: Perceptive Behavioral Foundation Models for Humanoid Control via Unsupervised Reinforcement Learning
In submission, 2026. (* Equal contribution)
In submission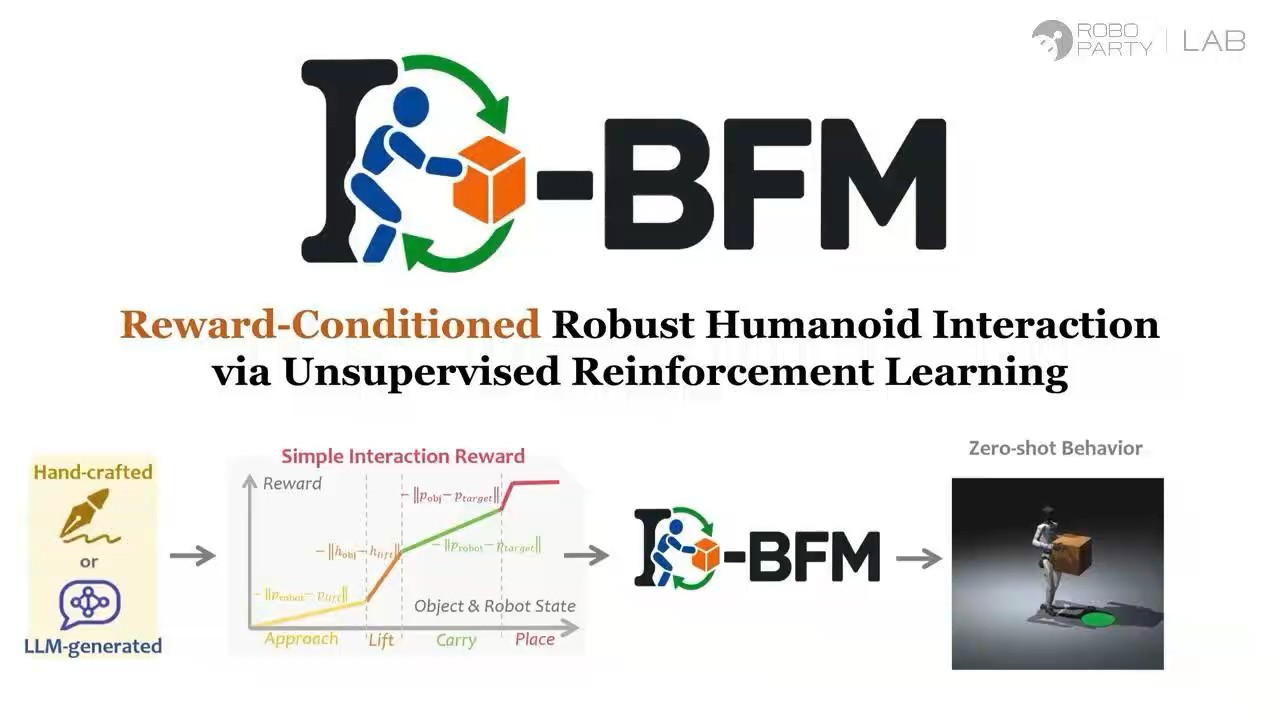
I-BFM: Reward-Conditioned Robust Humanoid Interaction via Unsupervised Reinforcement Learning
In submission, 2026. (* Equal contribution)
In submission
UFO: A General Unsupervised Reinforcement Learning Framework for Humanoid Control
In submission, 2026. (* Equal contribution)
Tech report
MimicLite: Efficient and Effective General Humanoid Motion Tracking
Technical report, 2026.
General motion tracking and whole-body teleoperation at roughly 1/200 to 1/2000 of SONIC's GPU-hours, with better global root tracking on a real Unitree G1.
Project
Selected projects at Zhejiang University and Beijing Jiaotong University
ZJU
Multi-Motion Humanoid Imitation Learning with Cross-Attention Dynamic Masking
A teacher–student–RL fine-tuning framework in which one policy performs walking, running, jumping, kicking, boxing, single-leg balance and squats (about 90% of AMASS). Goal inputs can be freely combined (CoM, hands, feet or whole body), and an adaptive motion curriculum with a multi-motion weighted network reduces conflicts and forgetting. Validated on a 1.8 m full-size humanoid.
ZJU
Motion Retargeting as Full Trajectory Optimization
Reformulated retargeting from per-frame gradient or IK solving into a full trajectory optimization problem with Pinocchio, CasADi and Acados, for both offline and online use. The result is smoother and more dynamically feasible than PHC, GMR and OmniRetarget, easing RL imitation and teleoperation.
ZJU
Centroidal-Dynamics NMPC for Humanoid Whole-Body Control
Upgraded single-rigid-body convex MPC to whole-body centroidal-dynamics NMPC with WBC on OCS2, adding an arm-momentum cost and control barrier functions, solved with DDP (iLQR) and SQP. Led to a granted invention patent.
ZJU
Wukong IVs Humanoid: Box Carrying, Stairs and Squats
RL locomotion based on DreamWaQ for box carrying, stair climbing and robustness, from tuning to real-robot acceptance tests; squat motions from dynamics-aware trajectory optimization with Pinocchio and OSQP. Also deployed on Wukong IV, a DEEP Robotics full-size humanoid and Fourier N1.
BJTU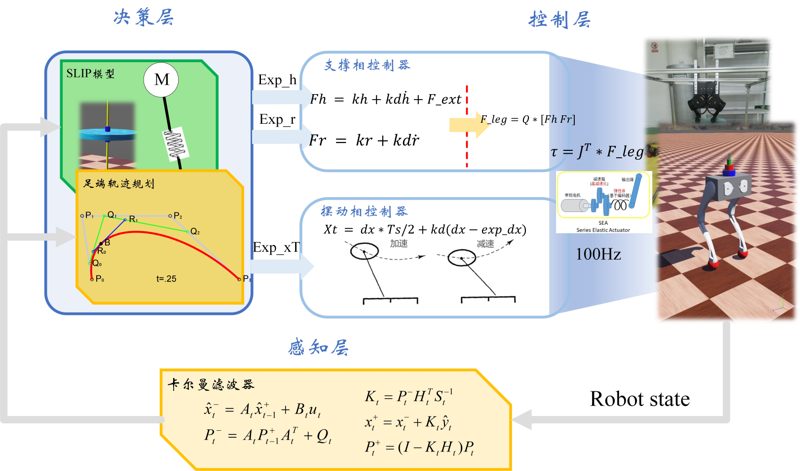
Point-Foot Biped Locomotion Control
Beijing Outstanding Graduation Design. Virtual model control, with the mechanical design, hardware selection, simulation and prototype built on my own, and Kalman-filter fusion of IMU and leg odometry.
BJTU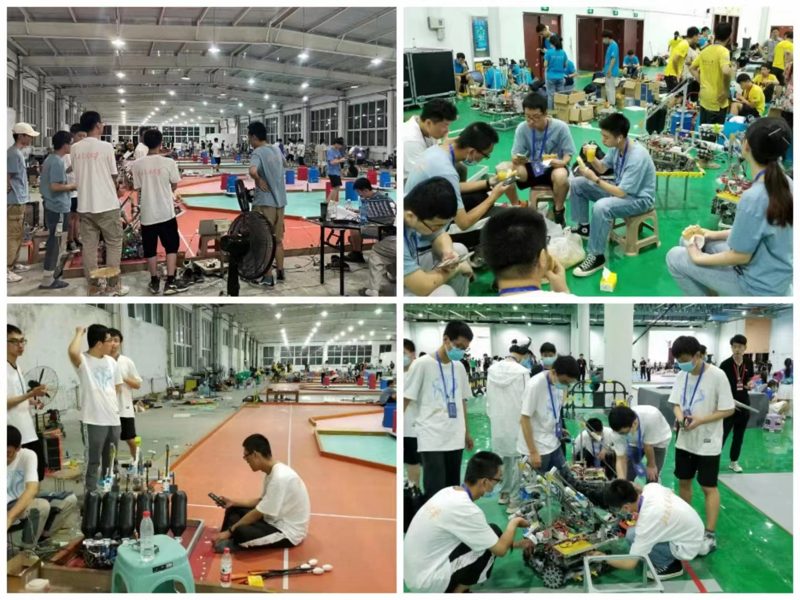
Robocon: National University Robot Competition
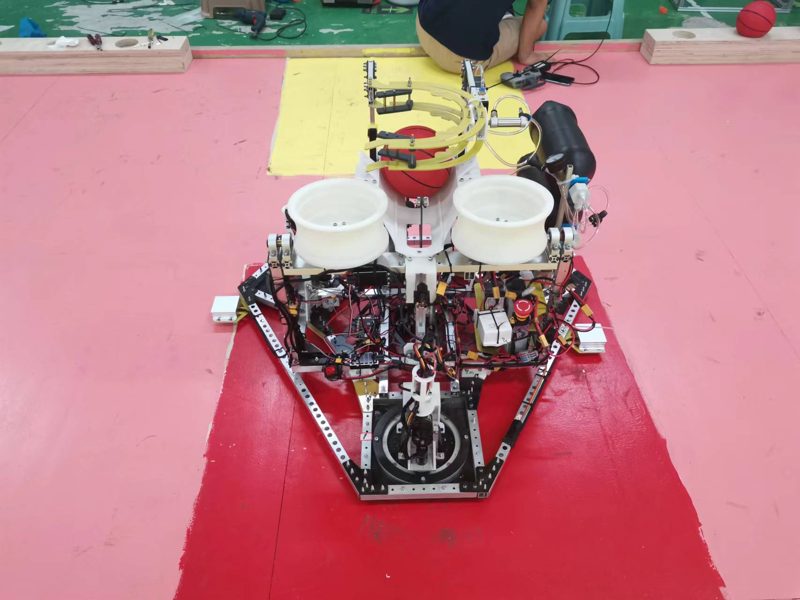
Three years of competition and two national second prizes and one third prize, serving as core member, electronics lead and team captain. Led a 40-person team and rebuilt its technical, management and training system from scratch.
Education & Experience
Now
Lead, RoboParty Lab · RoboParty
Open-source humanoid infrastructure and behavioral foundation models
2023.09 – 2026.03
M.S. in Control Engineering · Zhejiang University
Robotics and Machine Intelligence Lab, advised by Prof. Qiuguo Zhu
2024.09 – 2024.11
Intern · Honor, New Industry Incubation
Quadruped, wheel-legged and quadruped-arm RL environments in IsaacLab (DreamWaQ, PIE)
2019.09 – 2023.06
B.E. in Measurement & Control Technology and Instruments · Beijing Jiaotong University
Robocon team captain; national innovation project leader
Awards
- First-author journal paper: Cooperative Motion Control of Wheel-Legged Robot, Robotica
- Granted Chinese invention patent CN119407787A: whole-body coordinated control of humanoid robots based on a centroidal dynamics model (with Prof. Qiuguo Zhu)
- Beijing Outstanding Graduation Design, 2023
- Special-Class Scholarship, Beijing Jiaotong University
- National-level rating, College Students' Innovation Project (wheel-legged quadruped), project leader
- Robocon National University Robot Competition: second prize (×2), third prize (×1)